
Technical Analysis of the Mars Pathfinder Mission (Sojourner Rover)
- Mission Designation: Mars Pathfinder
- Rover Vehicle: Sojourner (Microrover Flight Experiment - MFEX)
- Operating Agency: NASA (Jet Propulsion Laboratory)
- Launch Date: December 4, 1996
- Landing Date: July 4, 1997
- Launch Vehicle: Delta II 7925
- Landing Site: Ares Vallis (19.13°N, 33.22°W)
- Status: Mission Completed (Successful)
1. Mission Objectives
The Mars Pathfinder mission was primarily conceived as a technology demonstration under the "Faster, Better, Cheaper" philosophy. Its objectives were divided into two categories:
Engineering and Technology:
- Validate a new passive Entry, Descent, and Landing (EDL) system using parachutes and an airbag cushioning system.
- Demonstrate the feasibility of a semi-autonomous mobile explorer vehicle (rover) on the Martian surface.
- Establish direct Earth-Lander and UHF Rover-Lander communication links.
Scientific:
- Characterize the geomorphology and geology of the Ares Vallis landing site, an ancient floodplain.
- Analyze the elemental composition of Martian rocks and soil in situ.
- Study the magnetic and mechanical properties of surface dust.
- Monitor atmospheric meteorology and the thermal structure of the lower atmosphere.
2. Spacecraft Specifications (Sojourner Rover)
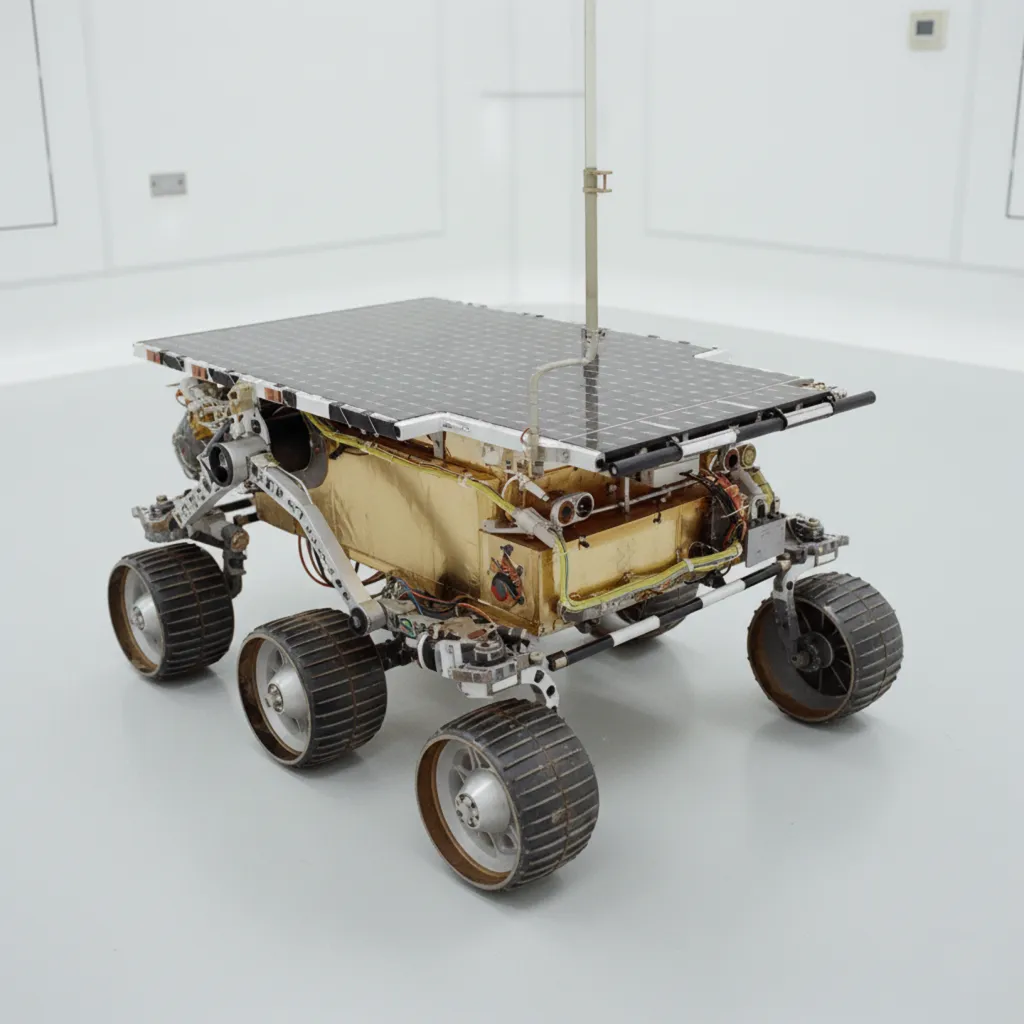
Sojourner was a six-wheeled vehicle pioneering planetary robotics.
- Mass: 10.6 kg (11.5 kg with auxiliary deployment equipment).
- Dimensions: 65 cm long, 48 cm wide, 30 cm high.
- Mobility System: 6-wheel "Rocker-Bogie" suspension (13 cm diameter each), allowing it to overcome obstacles up to 20 cm and slopes of 45 degrees. Each wheel had independent traction.
- Speed: Maximum of 1 cm/s, with an operational average of 0.4 cm/s.
- Power: Top-mounted Gallium Arsenide/Germanium solar panel (0.22 m²) generating ~16W peak. Primary (non-rechargeable) Lithium Thionyl Chloride (LiSOCl2) batteries for night operations and peak demand.
- Computing: Intel 80C85 8-bit processor at 2 MHz (approx. 0.1 MIPS), with 512 KB of RAM and 176 KB of flash memory.
- Thermal Control: Radioisotope Heater Units (RHU) and aerogel insulation to protect electronics from the Martian cold (-110°C).
3. Scientific Instrumentation
The rover and the lander (renamed Carl Sagan Memorial Station) carried complementary instruments:
On the Sojourner Rover:
- Alpha Proton X-ray Spectrometer (APXS): Mounted on a rear deployment mechanism, it allowed determining the elemental composition of rocks and soil (detecting elements such as carbon, oxygen, magnesium, silicon, iron, etc.).
- Cameras: Two frontal monochrome cameras for stereoscopy and navigation, and one rear color camera (Kodak KAI-0371 CCD).
- Technological Experiments: Wheel abrasion sensors, material dust adherence (using a crystalline quartz solar cell), and accelerometers.
On the Lander (Reference):
- IMP Camera (Imager for Mars Pathfinder): Multispectral stereo camera for panoramas and atmospheric opacity study.
- ASI/MET Meteorology Package: Pressure, temperature, and wind sensors at different heights on a mast.
4. Launch Vehicle
The mission used a McDonnell Douglas Delta II 7925 rocket.
- First Stage: RS-27A engine with LOX oxidizer and RP-1 fuel, assisted by 9 GEM-40 solid fuel boosters.
- Second Stage: AJ10-118K engine (Aerozine-50/N2O4), responsible for Earth orbit insertion and part of the trans-Mars injection.
- Third Stage (PAM-D): Star-48B solid fuel motor, used for the final escape burn towards Mars.
5. Development and Results Analysis
- Landing (EDL): On July 4, 1997, the probe entered the atmosphere directly. The airbag system worked perfectly; the spacecraft bounced at least 15 times, reaching up to 15 meters in height, before coming to a stop.
- Deployment: The lander petals opened, uprighting the spacecraft. Sojourner descended via a deployable ramp on Sol 2.
- Surface Operations: Designed for 7 sols, the rover operated for 83 sols. It traveled approximately 100 meters in total around the lander, exploring rocks named "Barnacle Bill", "Yogi", and "Scooby Doo".
- Key Discoveries:
- APXS analysis of the "Barnacle Bill" rock revealed high silica content, suggesting it was andesite. This indicated Mars had a more complex and differentiated volcanic history than expected (reheated and remelted crust).
- Conglomerates and rounded pebbles were identified, confirming that Ares Vallis was carved by catastrophic floods of liquid water in the past.
- Thermal data suggested large temperature fluctuations (from -8°C to -70°C in a single day).
- End of Mission: Final contact was made on September 27, 1997. It is suspected that the lander's battery depleted, preventing the electronics from maintaining temperature, which led to communications system failure. The rover likely continued operating for a time in contingency mode, circling the lander awaiting commands that never arrived.
6. Technical Conclusion
Mars Pathfinder was a resounding success that revolutionized planetary exploration. It demonstrated that high-level science is possible with limited budgets (approx. 265 million USD at the time). The Sojourner rover, though small, validated the "Rocker-Bogie" mobility technology that would become the foundation for future MER (Spirit/Opportunity) and MSL (Curiosity) rovers. Scientifically, it cemented the hypothesis of an ancient wet and warm Mars.
Related
Missions
- 🛰️ Mars Pathfinder
- 🛰️ Curiosity
- 🛰️ Opportunity
Events
- 📅 Launch of Sojourner 4 DEC 1996 · 12:00 UTC · SOL 23 OF CHRYSIO OF YEAR 23
- 📅 Mars Arrival of Sojourner 4 JUL 1997 · 12:00 UTC · SOL 6 OF ISIDO OF YEAR 23
- 📅 Deployment of the first rover Sojourner 6 JUL 1997 · 12:00 UTC · SOL 8 OF ISIDO OF YEAR 23
- 📅 End of mission: Sojourner 27 SEP 1997 · 12:00 UTC · SOL 14 OF KASEO OF YEAR 23
Marspedia terms
- 📖 EDL
- 📖 Spectrometer
- 📖 Delta
- 📖 MER
- 📖 Spirit
- 📖 Ares Vallis